RECENTLY CHECKED
All projects →
CAIBI ASSESSMENT

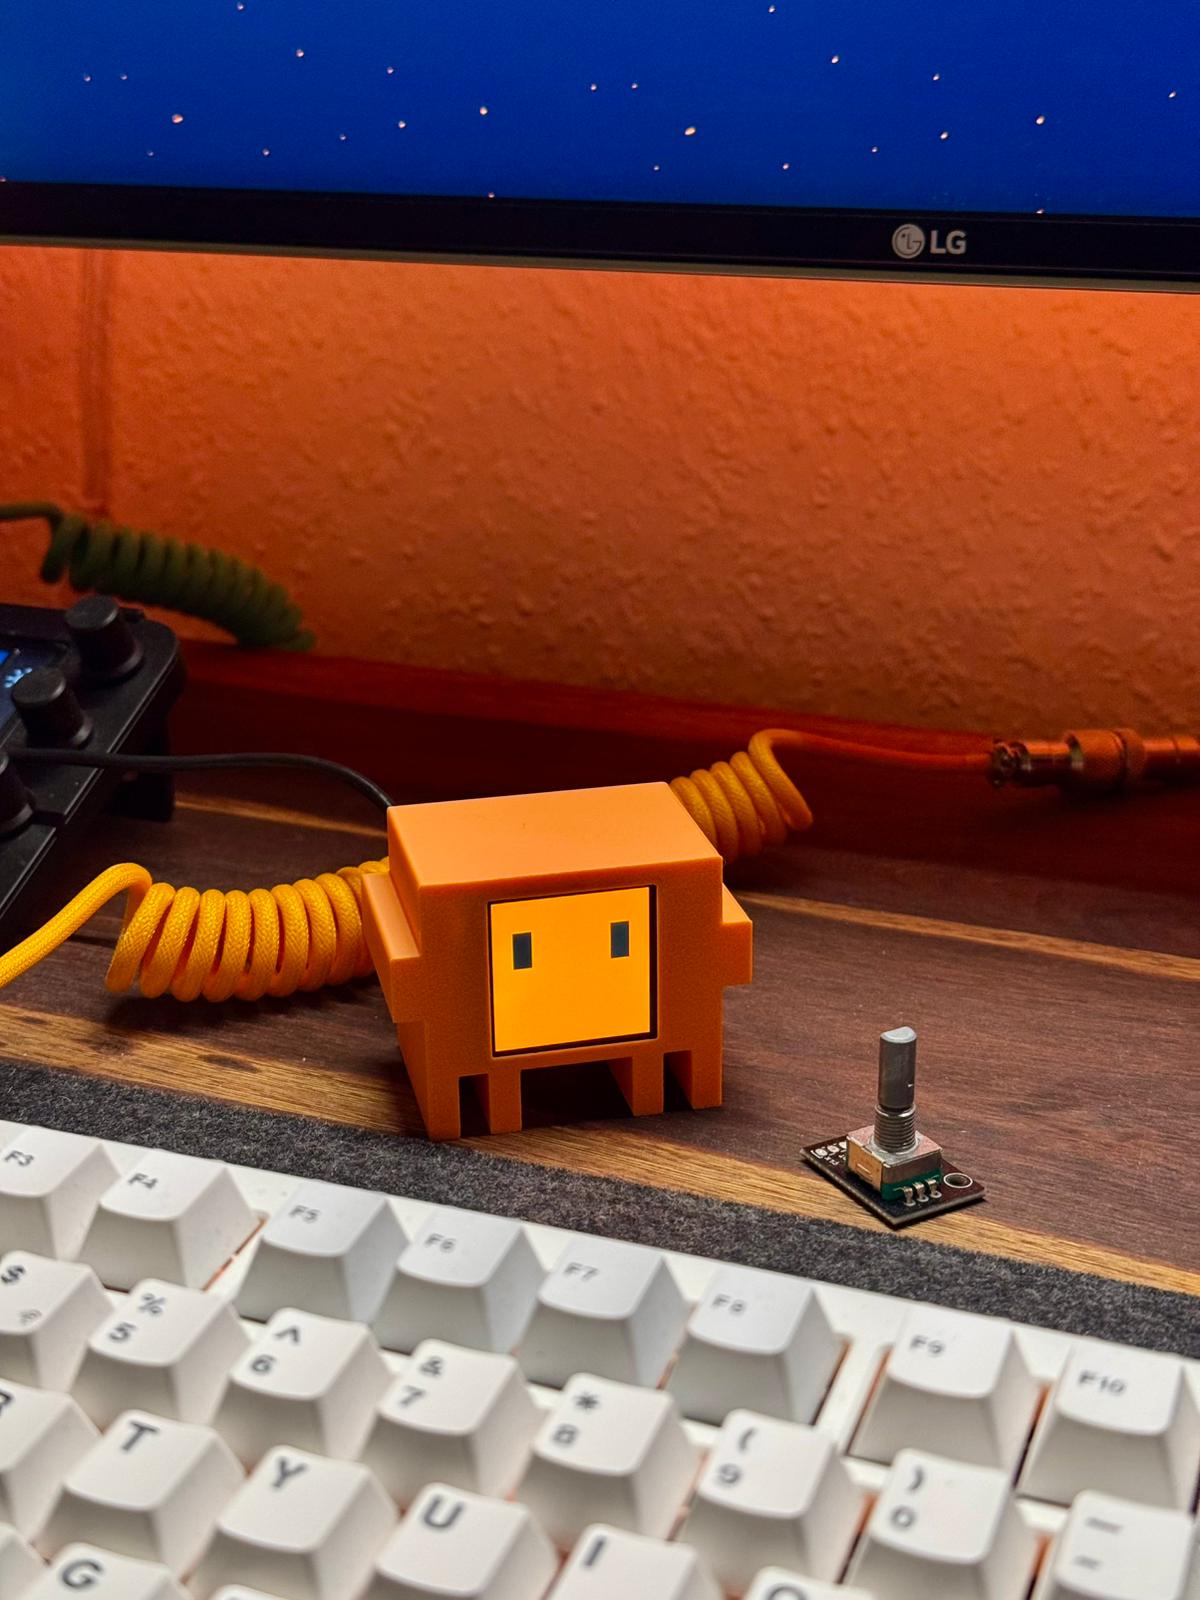
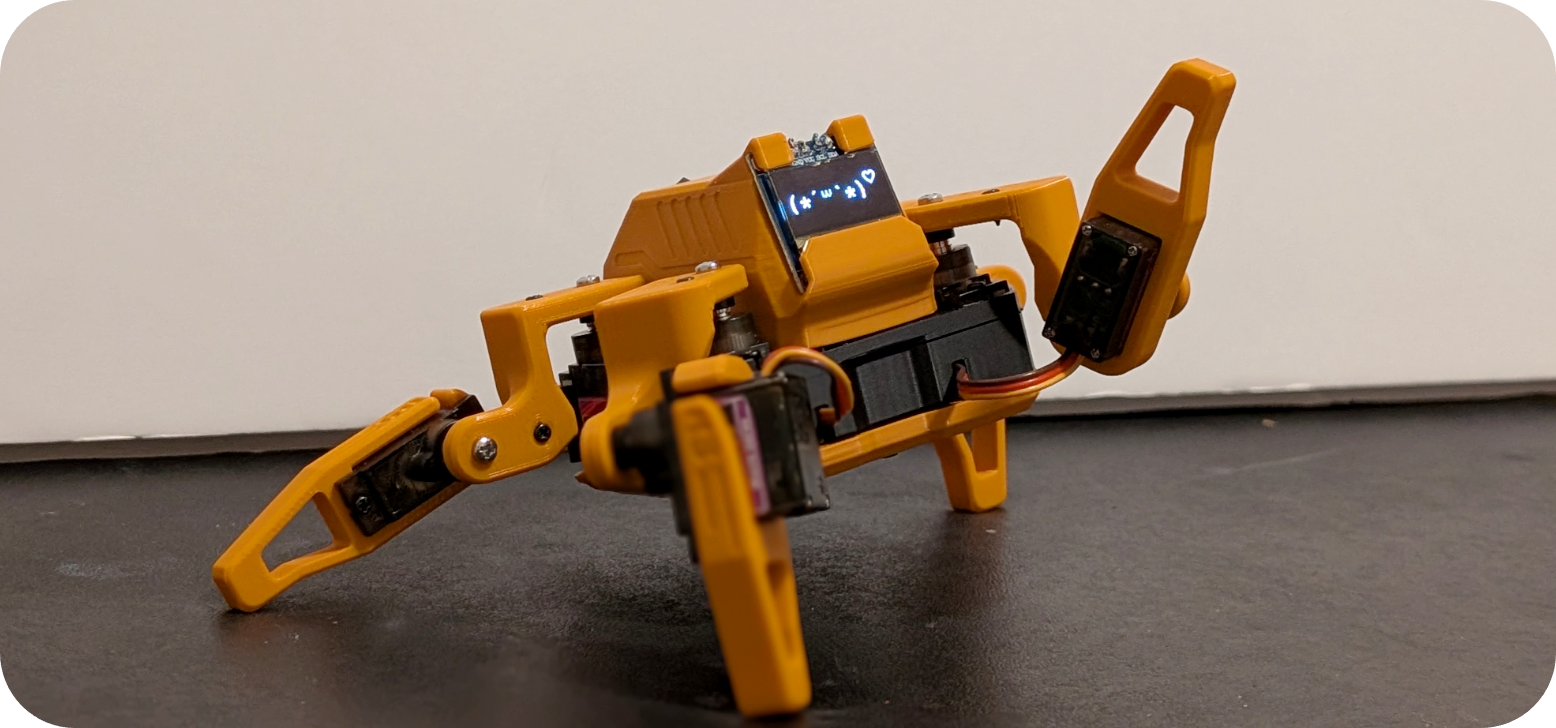
Sesame Robot

CAIBI VERDICTWORTH CONSIDERING

A printable ESP32 quadruped using eight servos, an expressive OLED face and open animation/control software.

Build or buy?

Compare the documented build with the purchase reference.

Build it yourself

Build estimate£37–£44Source estimate · high confidenceOne robot; published parts route
Time
Weekend+
Difficulty
4/5
Physical processes
3D printer · Soldering
See build requirements →

Purchase reference

Buy price reference£214Petoi Bittle programmable robot dogRecorded 5 Sep 2026

Check the source for the exact model, availability and what is included.

Check comparison evidence →
Build estimate is lower
What the prices cover

Creator-published total parts range, with GBP shown as an approximate conversion.

Includes: Published robot hardware and printed-part material.

Not included: 3D printer ownership; Shipping; Optional batteries or upgrades.

Build evidence recorded 4 Sep 2026. Currency conversions are approximate.

Petoi Bittle is the nearest straightforward bought comparison, not an identical robot. The difference shown is parts cash only and does not price printing time, assembly or calibration.

GLOBAL purchase/source reference ↗
BUILD AT A GLANCE

Source view and main parts

Check the source ↗
PHYSICAL BUILD5 key parts or groups
No.Source specification
01ESP32 based controller
028 × MG90 servos
03128 × 64 OLED display
045V 3A power source or supported battery setup
053D printed PLA parts
Full source specifications
  1. ESP32 based controller
  2. 8 × MG90 servos
  3. 128 × 64 OLED display
  4. 5V 3A power source or supported battery setup
  5. 3D printed PLA parts
TOOLS / PROCESSES2 involved
  • 3D printer
  • Soldering
The real-world workYOU STILL HAVE TOThe real-world work
  • Print the mechanical parts
  • Wire and fit the eight servos
  • Assemble the joints and body with the required clearances
  • Calibrate movement on the physical robot
  • Verify that it moves reliably without binding, slipping or tipping
THE BUILD SEQUENCE

How it comes together

1Preparation

  1. Gather the hardware

    Choose the supported controller route, eight MG90 servos and the power setup from the project BOM.

    YOU
  2. Print the robot

    Print the published PLA parts. The source is designed for minimal supports.

    YOU

2Build and assembly

  1. Build and wire it

    Assemble the frame and connect the servos, display, controller and power hardware using the published guides.

    YOU
  2. Flash and configure

    Load the firmware and configure the network and control setup. AI is useful here for code changes, configuration and debugging.

    AI + YOU

3Configure and test

  1. Make it your own

    Create poses, sequences, faces and integrations. This is where AI can add the most value after the base robot works.

    AI + YOU

Benchmark this project

Use the Sesame Robot prompt. Compare what different models deliver, then add what happened when you tried it.

Try this benchmark
View the project prompt

CAIBI adaptation · Prompt 1.0 · Project source

Open and copy prompt →

Benchmark results 0

No reviewed results yet for Sesame Robot. Add the first result →

AI IN THIS PROJECT

Get AI help on this build

CAIBI · AI CAN HELP

AI can help with

  • Firmware changes
  • Animation code
  • API integrations
  • Debugging
CAIBI · AI CAN'T DO

You still need to

  • Print the mechanical parts
  • Wire and fit the eight servos
  • Assemble the joints and body with the required clearances
  • Calibrate movement on the physical robot
  • Verify that it moves reliably without binding, slipping or tipping
Original source AI use and prompts
SOURCEThe original project does not publish an AI prompt

The prompts below are CAIBI helpers for this build. They are not presented as instructions from the creator.

CAIBI STARTING PROMPTS

Copy a prompt for this build

Each prompt tells AI to keep the original project source as the reference and to flag anything you must verify on the real build.

Ways to take it further
AFTER THE FIRST BUILD

Ways to take it further

New poses and routinesAlternative facesSensorsRemote controlDifferent enclosures and finishes
More routes and resources
OTHER WAYS TO GET THERE

You do not have to follow one route.

REVIEWED RESOURCES

Useful places beyond the main source

SOURCE · CAIBI · BUILDERS

What supports the verdict

CAIBIWORTH CONSIDERING

The result is a useful robotics platform rather than a one-off novelty. Hardware, movement, expressions and software can all be changed after the first build.

Evidence: Strong

Leave a build review
HAVE YOU MADE THIS?

Leave a build review.

First-hand evidence improves the assessment
What we want to know

What happened when you actually tried to make it.

  • Did it work?
  • Actual time and cost
  • What did you change?
  • What was harder than the source suggested?
  • Would you build it again?